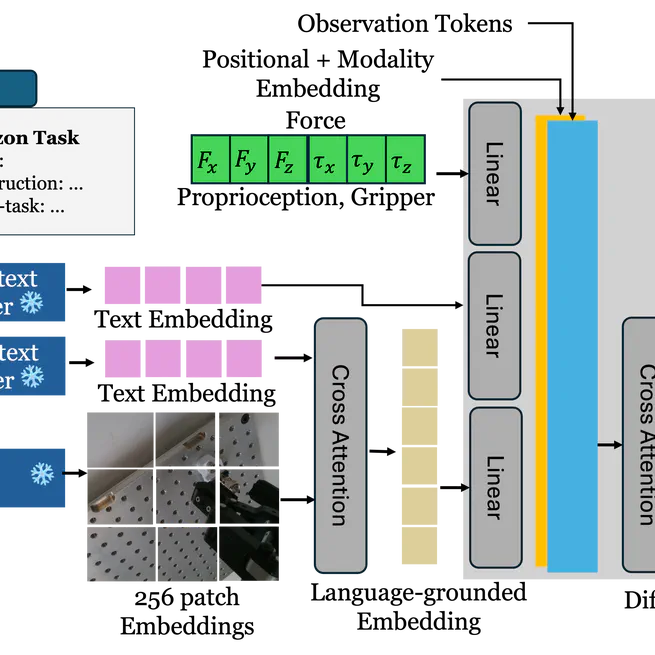
Language-grounded task selection and imitation learning for long-horizon robotic disassembly across diverse connectors and assembly configurations.
Sep 15, 2026